博士研究生 · 新加坡国立大学

LI Peizhuo李培卓

我研究如何让足式机器人在复杂环境中感知、决策并可靠工作。

我的研究聚焦强化学习与主动感知全身控制的交叉方向,致力于构建走出实验室后依然能够可靠工作的自适应机器人系统。

研究方向
  • 足式机器人
  • 强化学习
  • 主动感知全身控制

02 / 研究方向

让机器人在真实世界中可靠工作。

我构建连接感知与动作的学习控制系统,重点关注机器人在非结构化环境中的可靠性、适应性与可部署性。

01

主动感知全身控制

融合视觉、本体感知与主动观测,让机器人围绕地形与任务协调全身行为。

02

自适应机器人学习

研究强化学习方法,使策略迁移至真实机器人后仍保持鲁棒性、响应能力与适应性。

03

移动操作协同

通过分层策略协调移动与操作,使足式机器人能够完成需要全身配合的任务。

03 / 论文成果

代表性研究成果

近期工作覆盖人形与四足机器人运动、强化学习以及全身控制。

重点成果

研究项目预览: TAGA: Terrain-aware Active Gaze Learning for Generalizable Agile Humanoid Locomotion

Under review · 2026

TAGA: Terrain-aware Active Gaze Learning for Generalizable Agile Humanoid Locomotion

LI Peizhuo*, Hongyi Li*, Mingfeng Fan*, et al.

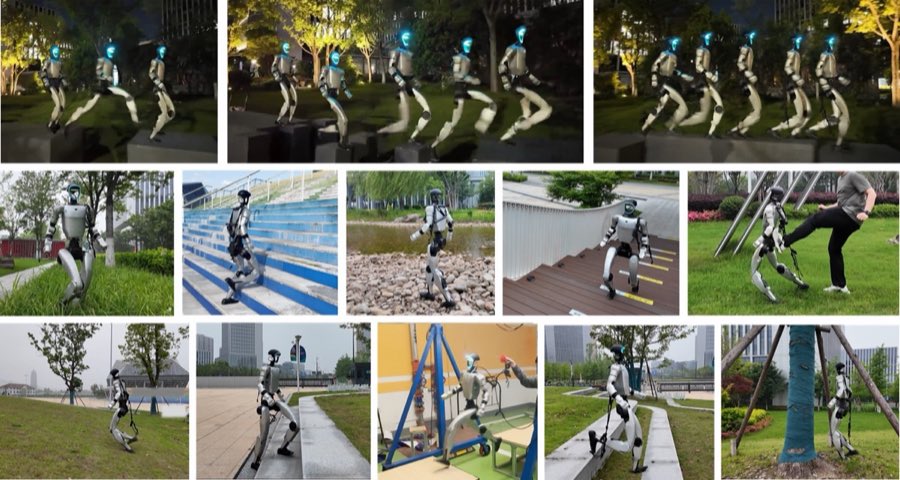
通过地形感知的主动视觉,让人形机器人预判落脚区域,并在未知地形上保持敏捷运动。

研究项目预览: KiVi: Kinesthetic-Visuospatial Integration for Dynamic and Safe Egocentric Legged Locomotion

IEEE/RSJ IROS · 2026

KiVi: Kinesthetic-Visuospatial Integration for Dynamic and Safe Egocentric Legged Locomotion

LI Peizhuo*, Hongyi Li*, Yuxuan Ma*, et al.

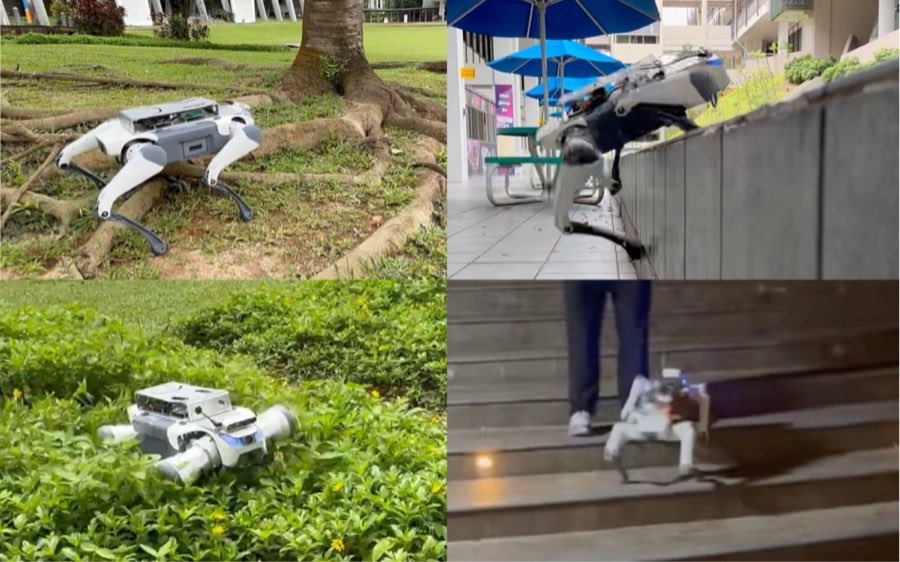
融合本体感知与视觉空间信息,实现动态、安全且以机器人为中心的四足运动。

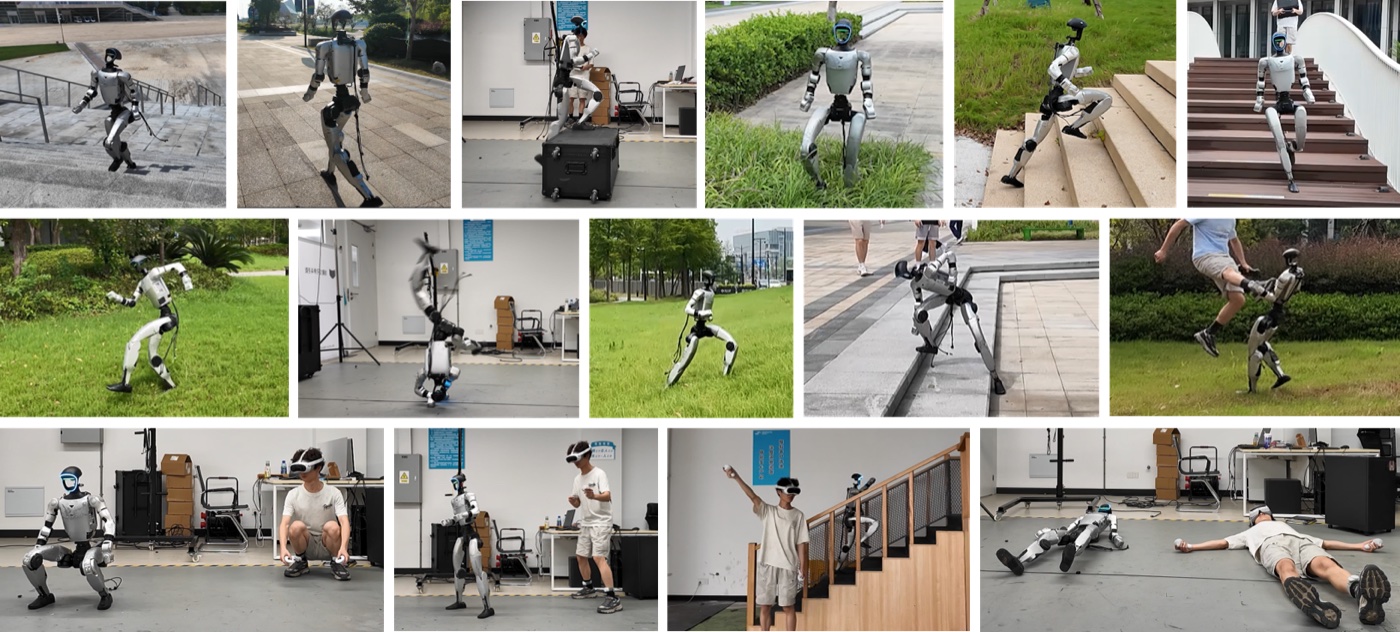
研究项目预览: PGMT: Perceptive General Motion Tracking for Humanoid Robots

arXiv preprint · 2026

PGMT: Perceptive General Motion Tracking for Humanoid Robots

Hongyi Li, LI Peizhuo, Yucheng Tao, et al.

统一的感知策略在复杂地形上追踪多样化全身动作,并支持运动、遥操作与跌倒恢复。

全部论文

14 篇 · 滚动查看

在 Google Scholar 查看完整列表
01

PGMT: Perceptive General Motion Tracking for Humanoid Robots

Hongyi Li, LI Peizhuo, Yucheng Tao, et al.

arXiv preprint · 2026

02

TAGA: Terrain-aware Active Gaze Learning for Generalizable Agile Humanoid Locomotion

LI Peizhuo*, Hongyi Li*, Mingfeng Fan*, et al.

Under review · 2026

03

KiVi: Kinesthetic-Visuospatial Integration for Dynamic and Safe Egocentric Legged Locomotion

LI Peizhuo*, Hongyi Li*, Yuxuan Ma*, et al.

IEEE/RSJ IROS · 2026

04

LATS: Large Language Model Assisted Teacher-Student Framework for Multi-Agent Reinforcement Learning in Traffic Signal Control

Yifeng Zhang, LI Peizhuo, Tingguang Zhou, Mingfeng Fan, Guillaume Sartoretti

arXiv preprint · 2026

05

GPO: Growing Policy Optimization for Legged Robot Locomotion and Whole-Body Control

Shuhao Liao, LI Peizhuo, Xinrong Yang, et al.

arXiv preprint · 2026

06

FARE: Fast-Slow Agentic Robotic Exploration

Shuhao Liao, Xuxin Lv, Jeric Lew, et al., LI Peizhuo, et al.

arXiv preprint · 2026

07

Unicorn: A Universal and Collaborative Reinforcement Learning Approach Toward Generalizable Network-Wide Traffic Signal Control

Yifeng Zhang, Yilin Liu, Ping Gong, LI Peizhuo, Mingfeng Fan, Guillaume Sartoretti

IEEE T-ITS · 2026

08

HeLoM: Hierarchical Learning for Whole-Body Loco-Manipulation by a Hexapod Robot

Xinrong Yang*, LI Peizhuo*, et al.

Under review · 2026

09

HEADER: Hierarchical Robot Exploration via Attention-Based Deep Reinforcement Learning with Expert-Guided Reward

Yuhong Cao, Yizhuo Wang, Jingsong Liang, et al., LI Peizhuo, Guillaume Sartoretti

arXiv preprint · 2025

10

SATA: Safe and Adaptive Torque-Based Locomotion Policies Inspired by Animal Learning

LI Peizhuo*, Hongyi Li*, Ge Sun, et al.

Robotics: Science and Systems · 2025

11

CoordLight: Learning Decentralized Coordination for Network-Wide Traffic Signal Control

Yifeng Zhang, Harsh Goel, LI Peizhuo, Mehul Damani, Sandeep Chinchali, Guillaume Sartoretti

IEEE T-ITS · 2025

12

HeteroLight: A General and Efficient Learning Approach for Heterogeneous Traffic Signal Control

Yifeng Zhang, LI Peizhuo, Mingfeng Fan, Guillaume Sartoretti

IEEE/RSJ IROS · 2024

13

DecAP: Decaying Action Priors for Accelerated Imitation Learning of Torque-Based Legged Locomotion Policies

Shivam Sood, Ge Sun, LI Peizhuo, Guillaume Sartoretti

IEEE/RSJ IROS · 2024

14

Learning-based Hierarchical Control: Emulating the Central Nervous System for Bio-Inspired Legged Robot Locomotion

Ge Sun, Milad Shafiee, LI Peizhuo, Guillaume Bellegarda, Auke Ijspeert, Guillaume Sartoretti

IEEE/RSJ IROS · 2024

04 / 经历

在学习与实践中塑造研究。

教育经历

工作经历

2026.08 — 至今

算法实习生

EngineAI

深圳 · 现场办公

2025.12 — 2026.08

算法实习生

Galbot

北京 · 混合办公

2024.08 — 2025.05

学生助教

新加坡国立大学

ME5418 机器人机器学习 · ME5406 机器人深度学习