 RedNote
 NoSB
01
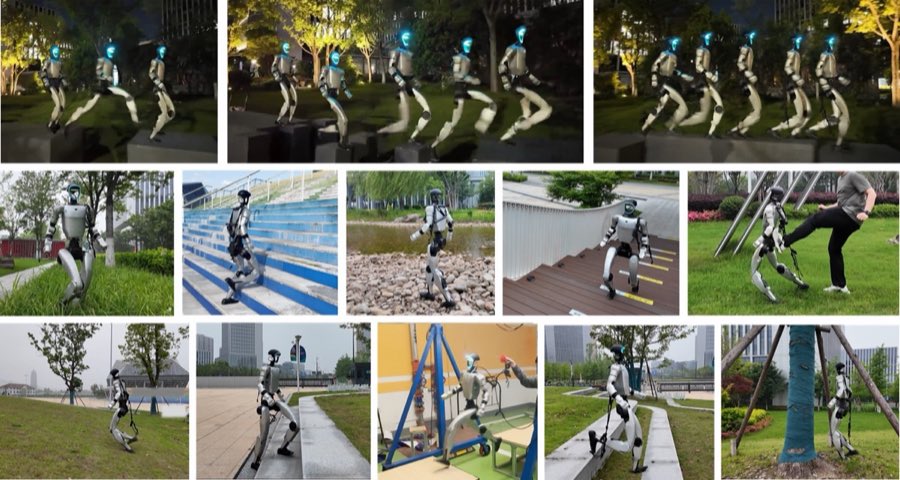
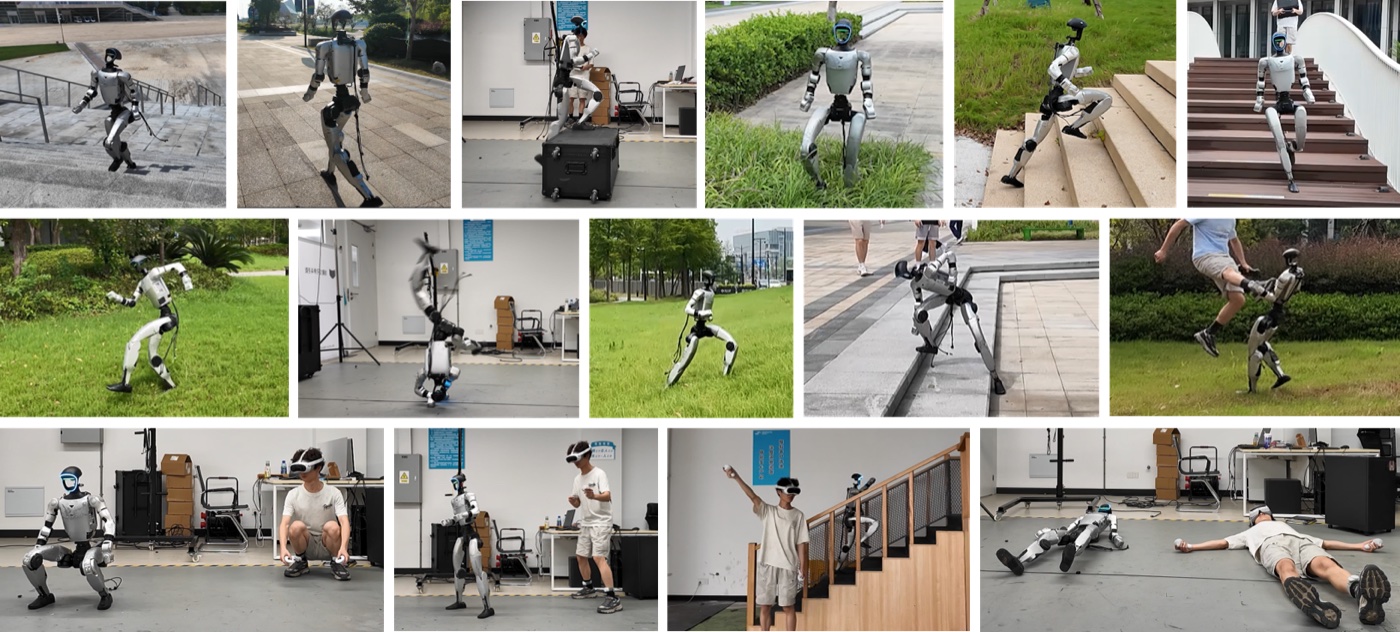
Active Perceptive Whole-Body Control
Integrating vision, proprioception, and active sensing so robots can coordinate their whole body around terrain and tasks.
PhD Researcher · National University of Singapore
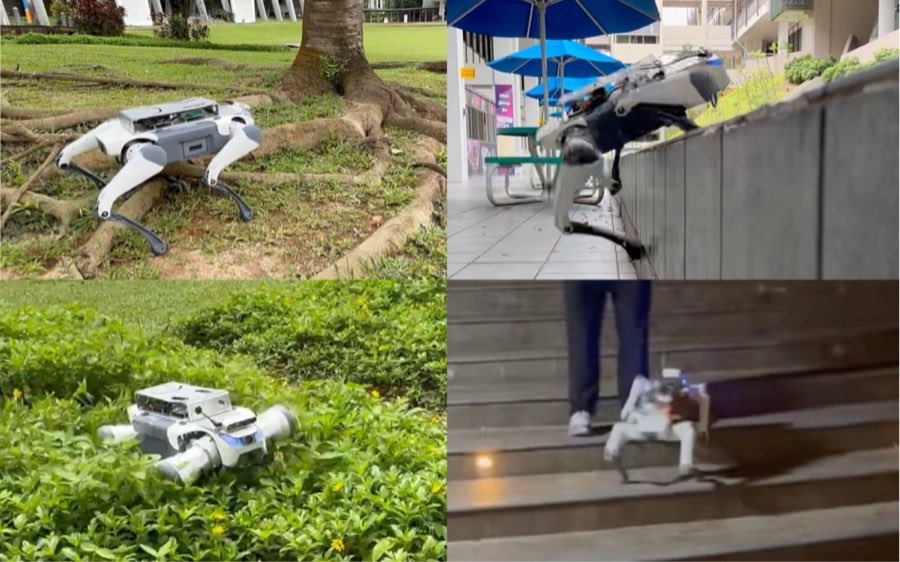
I study how legged robots can perceive, decide, and work in complex environments.
My research sits at the intersection of reinforcement learning and active perceptive whole-body control — building adaptive robotic systems that work reliably beyond the lab.
02 / Research
I build learning-based control systems that connect perception to action, with an emphasis on reliability, adaptability, and deployment beyond controlled settings.
Integrating vision, proprioception, and active sensing so robots can coordinate their whole body around terrain and tasks.
Developing reinforcement learning methods that remain robust, responsive, and adaptable when transferred to real robots.
Coordinating mobility and manipulation through hierarchical policies so legged robots can complete whole-body tasks.
03 / Publications
Recent work on humanoid and quadruped locomotion, reinforcement learning, and whole-body control.
Featured work
All publications
14 papers · Scroll
arXiv preprint · 2026
02Under review · 2026
03IEEE/RSJ IROS · 2026
04arXiv preprint · 2026
05arXiv preprint · 2026
06arXiv preprint · 2026
07IEEE T-ITS · 2026
08Under review · 2026
09arXiv preprint · 2025
10Robotics: Science and Systems · 2025
11IEEE T-ITS · 2025
12IEEE/RSJ IROS · 2024
13IEEE/RSJ IROS · 2024
14IEEE/RSJ IROS · 2024
04 / Journey
Education
Aug 2023 — Jun 2027 (expected)
May — Aug 2026
May — Aug 2025
2019 — 2023
Experience
Aug 2026 — Present
Sep 2025 — Present
Dec 2025 — Aug 2026
Jan 2024 — Sep 2025
Aug 2024 — May 2025